 EN
 IT Italiano
 ES Español
 FR Français
 DE Deutsch
Description
What it is
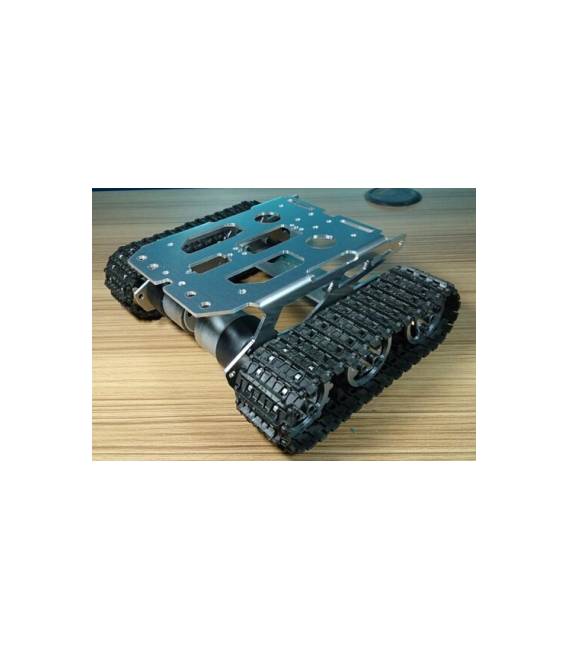
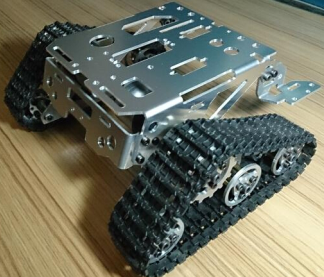
The TK002 Metal Base Rover Robot Frame with Belts is a fundamental component for mobile robotics projects. This base frame offers a robust and flexible structure that allows makers and robotics enthusiasts to create autonomous or remotely controlled rovers.
Features
- Metal frame for rover robot construction
- Includes belts
What it is for
Subscribers can use this base frame to create autonomous or remotely controlled mobile vehicles. It is ideal for projects that require the mounting of motors, sensors, and other components. Possible uses include simple rovers that move in a straight line in response to commands from a computer via serial monitor and vehicles that turn when detecting an obstacle.
Tutorial: How to use the TK002 Metal Base Rover Robot Frame with Belts
The TK002 Metal Base Rover Robot Frame with Belts is ideal for building an autonomous or remote-controlled mobile vehicle. This base component offers a robust structure on which to mount motors, sensors, and other necessary components for your project.
What you need
- Arduino Uno
- DC Motor with Gearbox
- L298N Motor Driver
- 7.4V Battery
- Position or Distance Sensors (check datasheet)
- Connectors and Cables
Steps
- Mount the DC motors on the frame supports using the provided screws.
- Connect the L298N motor driver to the motors and the Arduino control pin
- Connect the battery to the system to power the components
- Check that all connectors are securely connected
- Write the Arduino sketch to control the motors (see code)
- Mount additional sensors such as distance or tilt sensors on the frame
- Test the rover in a safe environment
- Optimize the vehicle’s behavior based on your experiments
Example code
void setup() {
  Serial.begin(9600);
}

void loop() {
  // Codice di controllo dei motori qui (verifica sul datasheet)
}
Mini project
Create a simple rover that moves in a straight line and responds to commands from the computer via serial monitor. Set the vehicle to turn when it detects an obstacle.
Common mistakes
- Loose connections or short circuits
- Motors misalignment causing a misstep
- Battery insufficient to power the components
- Sensors improperly configured to not detect correctly
Recommended accessories
- Arduino Uno R3
- L298N motor driver
- DC motor with gearbox 12V
- Set of ultrasonic sensors HC-SR04
Frequently asked questions
How can I mount the chassis?
Follow the steps described in the tutorial carefully and use the provided tools to ensure that all components are securely soldered.
Which battery should I use?
A 7.4V battery is recommended, but check the specifications of your chassis and motors (check the datasheet).
Reviews
There are no reviews yet.