 EN
 IT Italiano
 ES Español
 FR Français
 DE Deutsch
Description
What it is
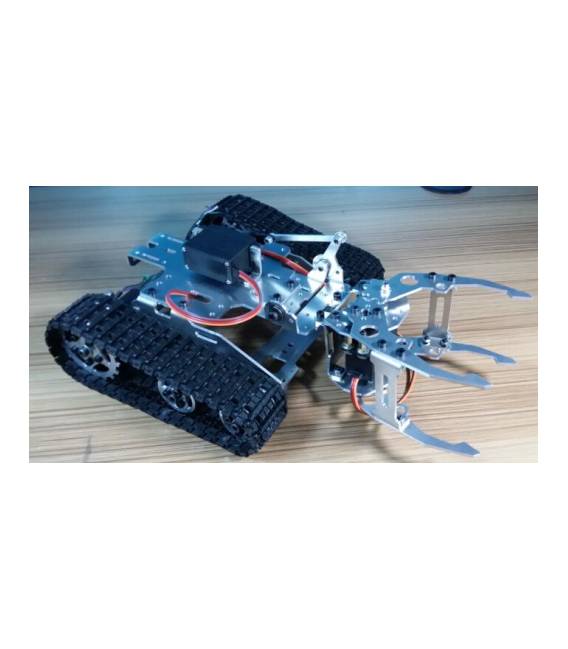
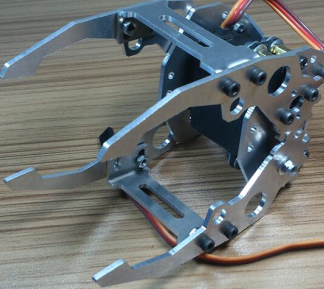
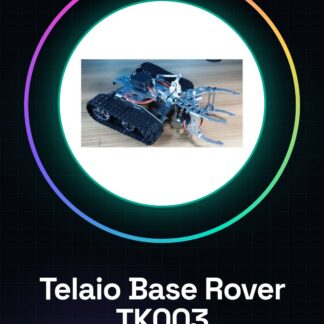
The TK003 Base Rover Robot Frame is a basic kit for building autonomous rover robots. This metal frame includes a claw and servomotors, providing makers with a solid structure on which to mount sensors, motors, and other components.
Features
- Base rover robot metal frame
- Claw included
- Servomotors included
What it is for
Ideally, this frame can be used to create a rover robot that moves autonomously, avoiding obstacles. It can integrate with ultrasonic sensors for distance detection from objects and the servomotors can control the rover’s movement. It is compatible with Arduino or ESP32 for programming.
Tutorial: How to Use the TK003 Metal Base Rover Robot Frame
The TK003 Metal Base Rover Robot Frame with Clamp and Servomotors is ideal for makers who want to create an autonomous vehicle. This frame offers a solid structure on which to mount sensors, motors, and other components.
What you need
- Arduino Uno or compatible
- 3S LiPo Battery
- Distance Sensors (ultrasonic or laser)
- Servomotors (if not included in the frame)
- JST Connectors
Steps
- Mount the servomotor on the frame clamp and ensure it is securely fastened.
- Connect the JST connectors to the servomotors and power controller (check the datasheet).
- Connect the Arduino Uno to the main board of the frame via the appropriate connector (check the datasheet).
- Install the necessary libraries for the sensors and servomotors on Arduino.
- Write a sketch that reads from the distance sensors and controls the direction of the servomotors based on the received data.
- Test the rover robot with a short test program (e.g., approach an object and back away).
- If necessary, adjust the connections or hardware to correct any operational errors.
- Customize the sketch based on the specific project requirements.
Example code
// Esempio di codice minimale
#include <Servo.h>
Servo myservo;
myservo.attach(9);
myservo.write(45);
Mini project
Create an autonomous rover robot that avoids obstacles. Use ultrasonic sensors to detect distance from objects and servomotors to control movement.
Common mistakes
- Incorrect connection of servomotors
- Libraries not installed correctly
- Distance sensors connected incorrectly
- Arduino not detected during library installation
Recommended accessories
- LiPo 3S 1000mAh battery
- Set of HC-SR04 ultrasonic sensors
- JST connection for servomotors
- Connectivity kit for Arduino Uno
Frequently asked questions
How can I control the servomotors?
Use the Servo.h library and the write() method to specify the angle of the servomotor.
What is the recommended battery?
A LiPo 3S with a capacity of at least 1000mAh.
Reviews
There are no reviews yet.