 EN
 IT Italiano
 ES Español
 FR Français
 DE Deutsch
Description
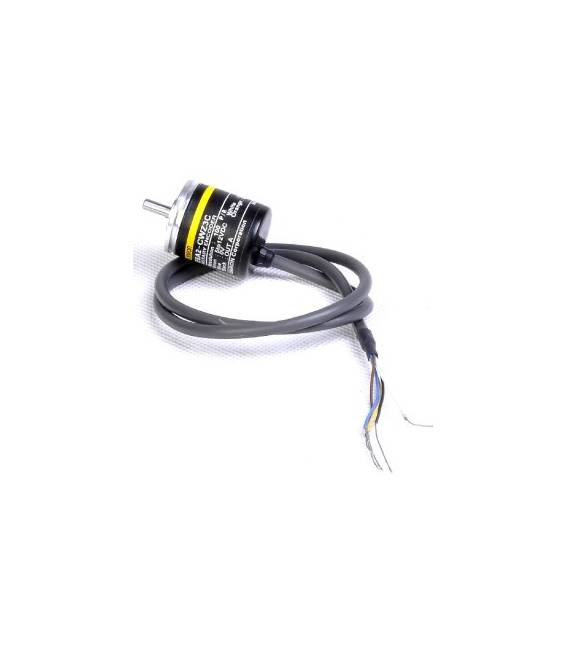
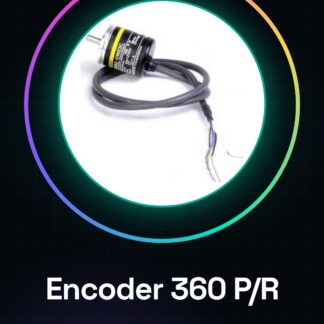
E6A2-CWZ3E Rotary Encoder 360 p / R
| Encoding Method | Incremental |
|---|---|
| Supply Voltage | DC5 to 12 V (ripple (pp): maximum 5%) |
| Absorption Current | 50 mA DC Max. |
| Pick-up Current | ca. 9A (time: approximately 0.3 ms) |
| Resolution (single turn type) | 360 P / R |
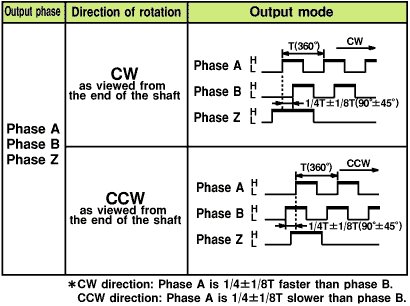
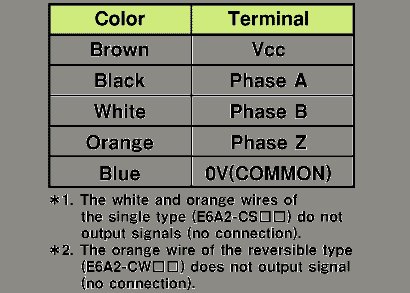
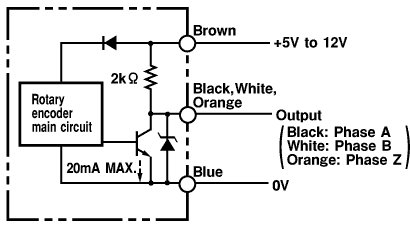
| Output Phases | A, B e Z |
| Control Output (Output Type) | NPN Voltage Output |
| Control Output (Output Resistance) | 2k |
| Control Output (Load Current) | 20 mA max. |
| Control Output (Residual Voltage) | 0.4 V CC max. (Load Current: at 20 mA max.) |
| Initial position point | Uninitialized |
| Max. response frequency | 30 kHz |
| Output phase difference | 90 ° -45 a +45 ° |
| Output rise and fall times | Output rise time: 1 s max. Output fall time: 1 s max. (Lead length: 500 mm, stray current: 10 mA) |
| Starting torque | Ambient temperature: 1 mN .m max. |
| Moment of inertia | 1 x 10 ** – 7 kg.m ** 2 max. |
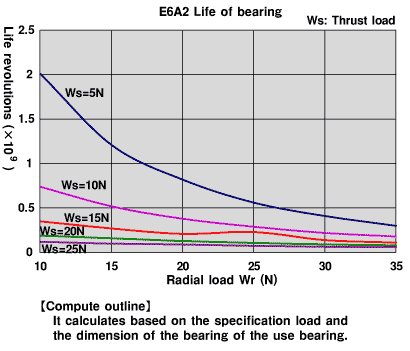
| Shaft loading | Radial: 10 N Axial: 5 N |
| Max. allowed rotation | 5000 r / min |
| Mechanical Life Expectancy | 100 million rotations min. |
| Ambient Temperature | In operation: from -10 to 55 Storage: from -25 to 80 |
| Ambient Humidity | In operation: from 35 to 85% relative humidity Storage: from 35 to 85% relative humidity |
| 20 MOhm min. at 500 VCC between charged parts and housing | |
| Dielectric Withstand Voltage | 500 V AC at 50/60 Hz for 1 minute between charged parts and case |
| Vibration Resistance | from 10 to 55 Hz, double amplitude 1.5 mm for 2 hours each in X, Y, and Z directions |
| Shock Resistance | 500 m / s ** 2 for 3 times each in X, Y, and Z directions |
| Degree of Protection | IEC60529: IP50 |
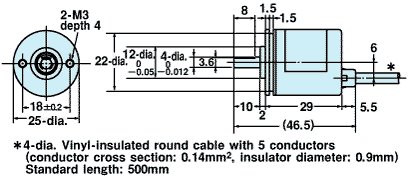
| Connection Method | Pre-wired Models (Cable Length: 0.5 m) |
| Material (Enclosure) | Aluminum Alloy |
| Material (Body) | Aluminum |
| Material (Shaft) | SUS420J2 |
| Material (Flat Spring) | – |
| Material (Mounting Bracket) | Zinc-plated Steel |
| Weight (Shipped Weight) | Approx. 35 g |
| Accessories | Instruction Manual, Joint, Hex Key, and Servo Mounting Bracket |
We have technical specifications for all components available. If not included in the product download sheet, send a message through the contact form and we will publish it as soon as possible on our website.
Tutorial: How to Use E6A2-CWZ3E
The rotary encoder E6A2-CWZ3E is ideal for measuring the rotation of a motor or mechanism. Useful for speed tracking projects and for those exploring sensors.
What you need
- Arduino or compatible
- Power supply cable
- 10kΩ resistor
- Soldering tip
Steps
- 1. Connect the encoder to pin A0 or A1 of the Arduino.
- 2. Attach the 10kΩ resistor between GND and VCC of the encoder.
- 3. Solder the GND, VCC and OUT pins of the encoder to the corresponding pins of the Arduino.
- 4. Load the provided Arduino code.
- 5. Check the motor rotation with the serial console.
- 6. Check the datasheet for further details.
- 7. Try reversing the GND and VCC connectors to see the effect.
- 8. Verify proper functioning with multiple turns.
Example code
```void setup() { Serial.begin(9600); pinMode(A0, INPUT); attachInterrupt(digitalPinToInterrupt(A0), count, CHANGE);}int count = 0;void loop() { if (digitalRead(A0) == HIGH) { count++; } Serial.println(count);}```Mini project
Create a rotating cart that moves according to the motor’s tilt.
Common mistakes
- Do not solder the pins correctly.
- Connect the encoder to an inappropriate pin.
- Omit the pull-up resistor.
- Forget to check the datasheet.
Recommended accessories
- DC motor
- Transmission
- Mechanical support
Frequently asked questions
How can I verify the correct functioning of the encoder?
Solder a GND and VCC connector to the encoder and verify the motor rotation with the serial console.
Can I use the encoder with a microcontroller other than Arduino?
Yes, the encoder is compatible with various microcontrollers.
What to do if the encoder does not work?
Check the connections and resistance. If problems persist, contact the supplier.
Reviews
There are no reviews yet.