 EN
 IT Italiano
 ES Español
 FR Français
 DE Deutsch
Description
What it is
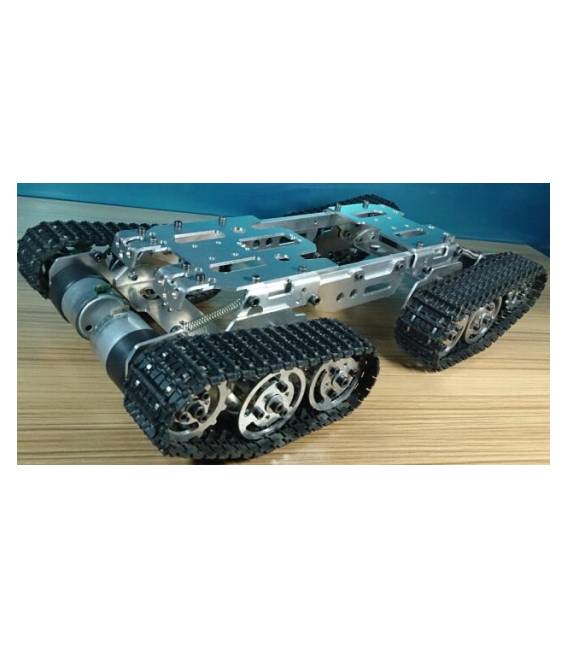
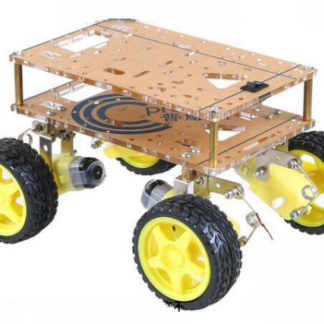
The Metal Base Rover Robot Frame with Cignie and TK004 Motors (SKU: ARD005908) is a robust metal structure designed for DIY robotics projects. Equipped with cignie and TK004 motors, it is the ideal base for building robots and autonomous vehicles.
Features
- Metal frame
- Integrated cignie
- TK004 motors
What it is for
This frame is perfect for creating rover that autonomously avoid obstacles. You can insert distance sensors and modify the Arduino sketch to program the rover’s movement around obstacles. It is suitable for both beginners and robotics experts.
Tutorial: How to use Metal Base Rover Robot Frame with Cignie and TK004 Motors
The base rover robot frame in metal is ideal for makers who want to create an autonomous or remote-controlled vehicle. This sturdy structure can be used as a base for advanced robotics projects, suitable for both beginners and experts.
What you need
- Arduino Uno
- 7.4V LiPo Battery
- L298N Controller
- Distance Sensors (check datasheet)
- Connectors and Cables
- Assembly Kit
Steps
- Install TK004 motors on the sides of the frame, ensuring a solid mounting.
- Connect the L298N controller to the motors following the provided documentation.
- Connect the Arduino Uno to the L298N controller to control the motor movements.
- Install and configure a distance sensor to avoid obstacles (check datasheet).
- Load an Arduino sketch that manages the rover’s movement based on data received from the sensors.
- Test the rover in a controlled environment before using it in open or complex environments.
Example code
// Uno sketch base per la gestione dei motori tramite Arduino
void setup() {
  pinMode(ENA, OUTPUT);
  pinMode(IN1, OUTPUT);
  pinMode(IN2, OUTPUT);
}

void loop() {
  digitalWrite(IN1, HIGH);
  digitalWrite(IN2, LOW);
  analogWrite(ENA, 200);
}
Mini project
Design an autonomous obstacle-avoiding rover. Insert distance sensors and modify the Arduino sketch to make it turn around obstacles.
Common mistakes
- Incorrect motor connection to the L298N controller
- Distance sensor not configured correctly
- Insufficient battery power
- Arduino program does not handle data from sensors
Recommended accessories
- Arduino Uno R3 – ARD005798
- L298N Controller – ARD006147
- 7.4V LiPo Battery – ARD005823
- HC-SR04 Distance Sensors – ARD005830
Frequently asked questions
What is the minimum voltage for the rover frame?
The recommended minimum voltage is 7.4V, provided by a LiPo battery.
Can I use another type of motor with this frame?
Yes, but make sure the motor is compatible with the connectors and the L298N controller.
Reviews
There are no reviews yet.