 EN
 IT Italiano
 ES Español
 FR Français
 DE Deutsch
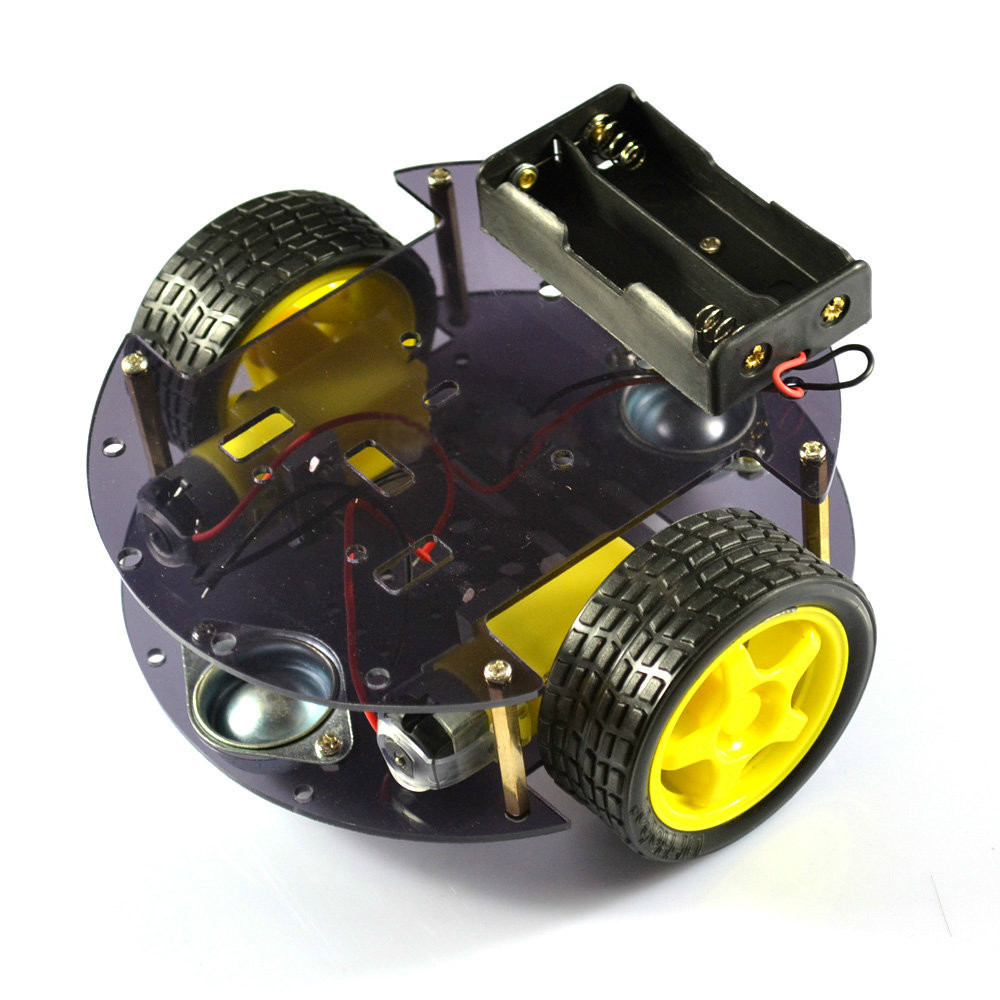
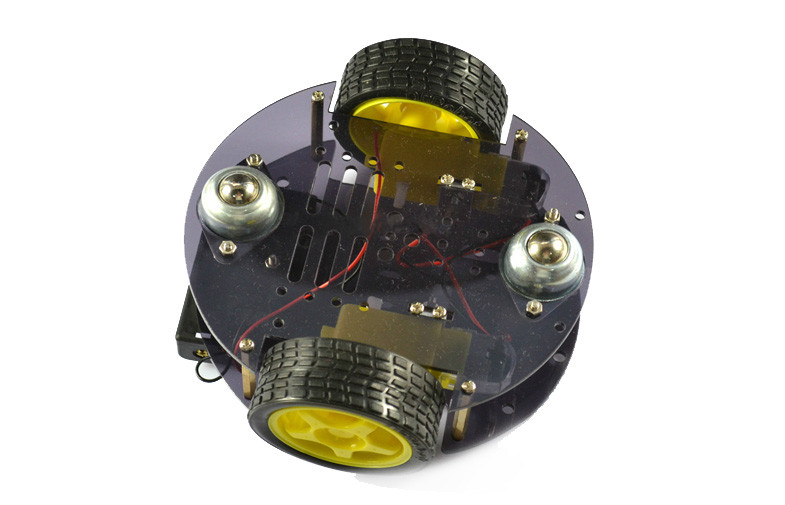
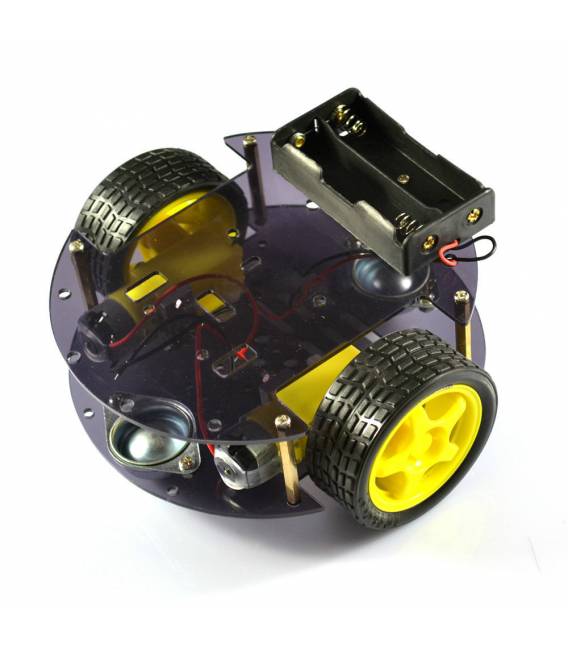
Description
What it is
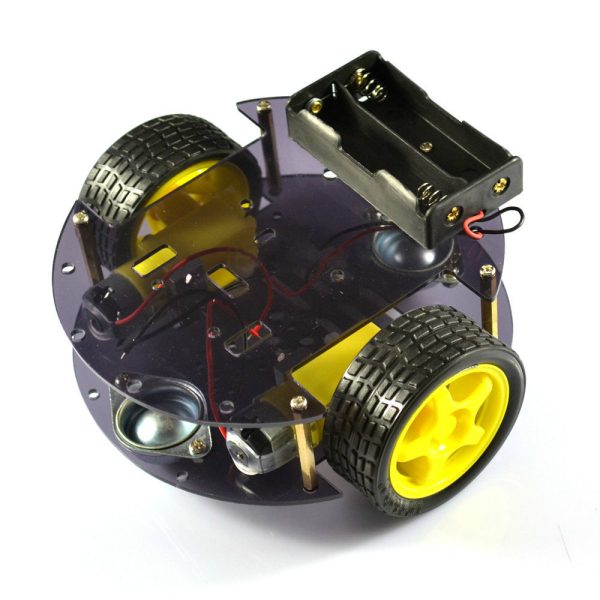
The Smart Car Spot 2WD Kit is a DIY chassis for a robot vehicle with 2 motors and omnidirectional wheels, designed for Arduino projects and electronic experiments. It is ideal for beginners and intermediates who want to build an autonomous robotic vehicle.
Features
- 2WD Robot Vehicle Chassis
- 2 N20 motors
- Omnidirectional Wheel
- Compatible with Arduino (check the datasheet)
What it is for
Allows you to build an agile and precise robotic vehicle. You can program it to move forward, backward, turn and change direction. Ideal for robotics experiments, programming learning and custom project development.
Tutorial: How to use Smart Car Spot Chassis DIY 2WD 2 N20 Motors + Omnidirectional Wheel Arduino
This robotic chassis is ideal for beginners and intermediates who want to build an autonomous robotic vehicle. With the two motors and the omnidirectional wheel, you can create a vehicle that moves agilely and precisely.
What you need
- Kit Smart Car Chassis DIY 2WD 2 Motors N20 + Omnidirectional Wheel Arduino
- Arduino UNO or compatible
- 7.4V LiPo Battery
- 2.5mm Power Cable
- Distance Sensors (optional)
- DC Motors (optional)
Steps
- 1. Check that all components are present in the kit.
- 2. Read the datasheet of the motors and the omnidirectional wheel carefully.
- 3. Connect the motors to the chassis using the power cables.
- 4. Attach the omnidirectional wheel to the chassis.
- 5. Mount the Arduino UNO or compatible on the chassis.
- 6. Connect the Arduino to the motors via the control cables.
- 7. Install the LiPo battery and ensure that the voltage is correct.
- 8. Load the Arduino code to control the motors.
Example code
```void setup() { // Inizializza i pin dei motori pinMode(2, OUTPUT); pinMode(3, OUTPUT);}void loop() { // Avvia i motori in avanti digitalWrite(2, HIGH); digitalWrite(3, LOW); delay(2000); // Arresta i motori digitalWrite(2, LOW); digitalWrite(3, LOW);}```Mini project
Build a robotic vehicle that moves forward for 2 seconds and then stops.
Common mistakes
- Do not read the motor datasheet carefully.
- Connect the motors in reverse.
- Do not ensure that the battery voltage is correct.
- Do not load the correct Arduino code.
Recommended accessories
- Distance sensors
- DC motors
- 7.4V LiPo battery
- Power cable 2.5mm
Frequently asked questions
Can I use an Arduino Mini
Yes, but make sure the pinout is compatible with the motors and the omnidirectional wheel.
How long does it take to assemble the chassis?
Assembly should take about 30-45 minutes, depending on your familiarity with electronic assembly.
Which sensors can I use to improve navigation?
You can use distance sensors like the HC-SR04 to improve navigation and the safety of the vehicle.
Does the chassis support other motors?
Check the datasheet to confirm motor compatibility.
Reviews
There are no reviews yet.