 EN
 IT Italiano
 ES Español
 FR Français
 DE Deutsch
Description
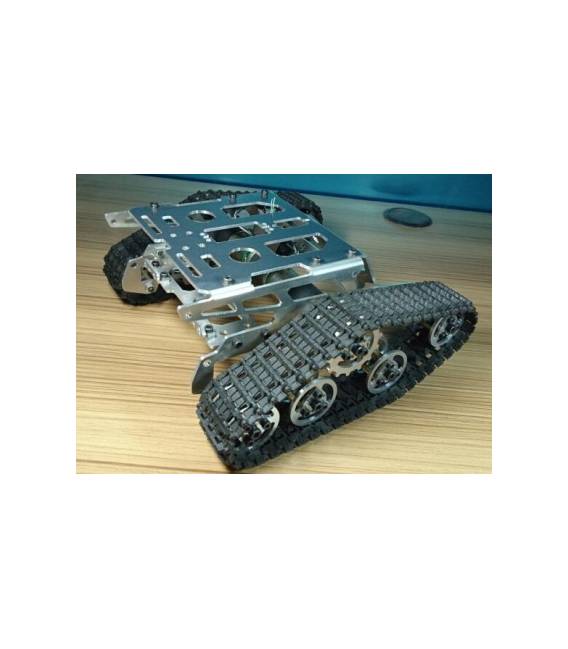
Base Rover Robot Frame Wali in Metal with TK001 Belts Product Description: As the trendy chassis frame, refined appearance, frame hook and wheel system are entirely made of metal, solid and stable, double electric traction motor (imported brushless motors, fully metal gears, with Hall speed sensor), powerful, fast and smooth travel, high stability, forward and backward, left and right rotation, standing and turning flexible features, there is a body in the middle reserved for the steering installation mouth for customers who install servos offers practicality, but the large section chassis platform allows customers to install the control circuit to provide insufficient space and the chassis has a hook under the platform, customers can use to install the battery.
Tutorial: How to Use the Metal Base Rover Robot Wali Frame with TK001 Belts
The metal base Rover Robot Wali frame is ideal for building a robust and flexible robotic vehicle. This metal frame, equipped with belts, is perfect for both beginners and more experienced makers looking to create custom rover projects.
What you need
- Arduino Uno
- DC Motor with sufficient torque
- L298N Motor Driver
- 7.4V Battery or equivalent
- Position and orientation sensors (optional)
- Connectors for power and data
Steps
- Mount the metal frame following the provided instructions.
- Connect the DC motors to the motor drivers L298N according to the driver documentation.
- Connect the position and orientation sensors (if used) to the Arduino circuit for accurate navigation.
- Configure the connection between the Arduino, motor drivers, and sensors according to the component specifications.
- Write the Arduino sketch to control the motors based on commands received from the navigation system.
- Test the mobility of the rover on a flat and safe surface.
- Calibrate the navigation system based on data collected from the sensors, if available.
- Customize the exterior appearance by adding protective components or specific tools for the project.
Mini project
Build a basic rover that can follow a black line on a white plane. Use line sensors and control the motors via Arduino.
Common mistakes
- Incorrect motor driver connection
- Imprecise navigation system configuration
- Insufficient sensor calibration
Recommended accessories
- L298N motor driver
- 7.4V battery
- Line sensors
- Various electrical connections
Frequently asked questions
Is the chassis suitable for outdoor rovers?
Yes, but make sure that the internal components are protected from extreme conditions.
Can I add a GPS navigation system?
Yes, just connect the GPS module to the Arduino’s serial port and write the appropriate sketch.
Reviews
There are no reviews yet.