 EN
 IT Italiano
 ES Español
 FR Français
 DE Deutsch
Description
What it is
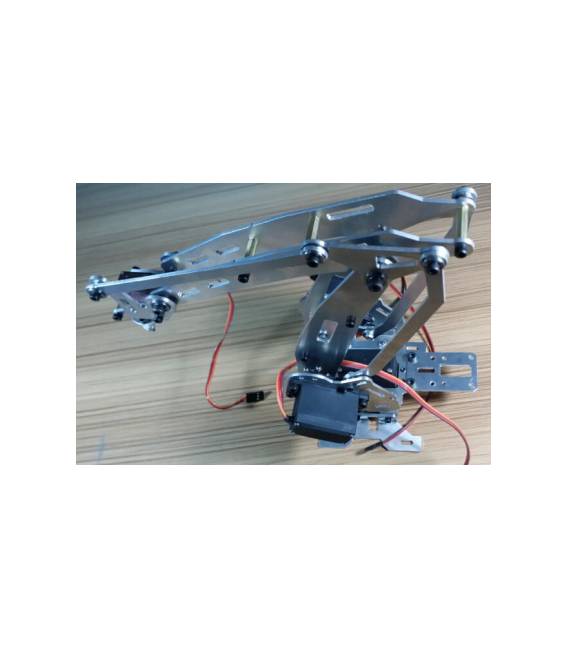
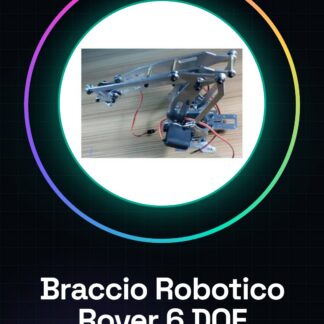
The Rover Car Arm 6 DOF Aluminum Robot Arm with TK011 Servomotors is an ideal component for robotics and automation projects. This arm, equipped with 6 degrees of freedom (DOF), allows for complex and precise movements.
Features
- 6 DOF for complex movements
- Aluminum for strength and lightness
What it is for
Suitable for rover, autonomous vehicle, and general robot projects. Ideal for object manipulation or interaction with complex environments.
Tutorial: How to use Rover Car Aluminum 6 DOF Robot Arm TK011
The Rover Car Arm in aluminum 6 DOF with servomotors is ideal for automation and robotics projects. It fits perfectly for makers looking for a robust and flexible support for experiments and prototypes. This robotic arm allows complex movements thanks to its 6 degrees of freedom, making it an excellent choice for applications such as object manipulation or interaction with real environments.
What you need
- Arduino Uno
- USB cable
- LiPo battery (check the datasheet)
- Servo motor connectors
- Assembly tool
Steps
- Connect the Arduino Uno to the computer via USB cable.
- Install the Servo library for Arduino.
- Connect the servomotors of the robotic arm to the pins of the Arduino (check the datasheet).
- Load the example sketch provided with the kit or create a new one following the instructions.
- Verify that the servomotors move correctly through the Arduino serial console.
- Further configure the robotic arm movements by modifying the base sketch.
- Test the robotic arm with a LiPo battery (check the datasheet) to ensure it works without USB power.
Example code
// Includi la libreria Servo
#include <Servo.h>
// Definisci i pin di connessione dei servomotori
const int servoPin1 = 9;
const int servoPin2 = 10;
// Crea oggetti per i servomotori
Servo myServo1;
Servo myServo2;
void setup() {
  // Collega i servomotori ai pin definiti
  myServo1.attach(servoPin1);
  myServo2.attach(servoPin2);
}
void loop() {
  // Esegui movimenti di base per testare il braccio robotico
  myServo1.write(90); // Posizione centrale del servomotore
  delay(500);
}
Mini project
Create a small rover with this robotic arm. Attach it to a mobile base and program it to perform basic movements such as picking up objects or interacting with the environment.
Common mistakes
- Connect the servomotors to the wrong pins.
- Do not configure the Servo library correctly.
- Use electrical voltage above the servomotors’ limit.
- Do not test the robotic arm with LiPo batteries before using it without USB power.
Recommended accessories
- LiPo battery for Arduino
- Serial connections for robotic arm monitoring
- Mobile base for rover (SKU: ARD005921)
- Electronic prototyping kit
Frequently asked questions
Can the robotic arm be used with other microcontrollers besides Arduino?
Yes, but it may require the installation of specific libraries for controlling servomotors.
What is the recommended minimum and maximum voltage for the servomotors?
Check the product datasheet to obtain these precise details.
Reviews
There are no reviews yet.