 EN
 IT Italiano
 ES Español
 FR Français
 DE Deutsch
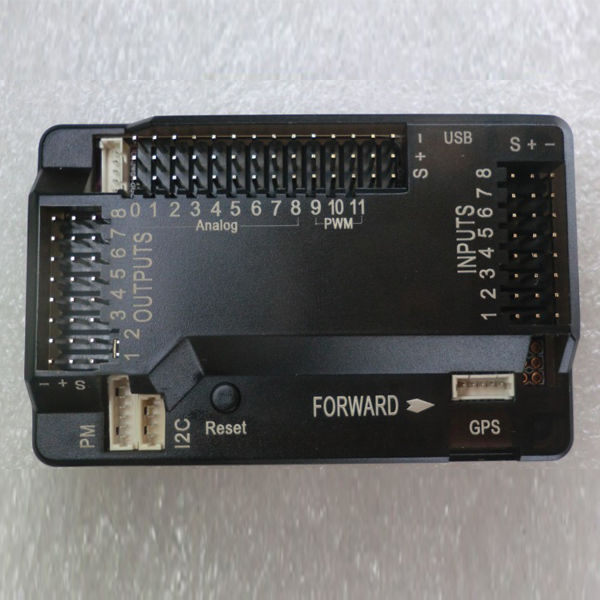
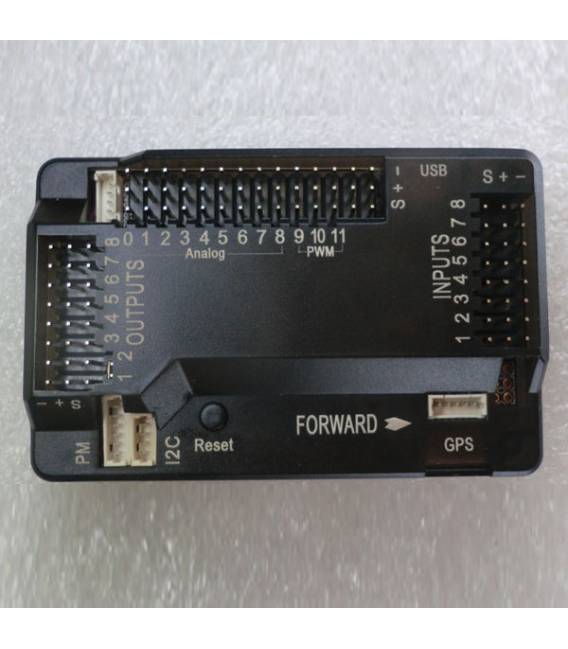
Description
What it is
The ARDUPILOT MEGA APM2.52 APM Flight Controller Board is a flight controller for drones and model aircraft. It offers advanced features for precise control and autonomous piloting.
Features
- Special design for ARDUPILOT MEGA APM2.52 APM Flight Controller Board
- SKU: ARD002148
- Price: 73.9 €
- Categories: Aereomodelling, Drones
What it is for
The ARDUPILOT MEGA APM2.52 is ideal for drone builders who want a stable and precise flight system. It can be used to build an autonomous quadcopter drone in 30 minutes by following the provided instructions.
Tutorial: How to use ARDUPILOT MEGA APM2.52
The ARDUPILOT MEGA APM2.52 is a flight controller for drones and model aircraft that offers advanced features such as roll, pitch, and yaw control. Ideal for drone builders who want a stable and precise flight system.
What you need
- Arduino Mega 2560
- IMU (Inertial Measurement Unit) Sensors
- LiPo Battery
- Propulsion motor
- Propeller
- Drone frame
Steps
- Check the hardware compatibility between the APM2.52 and your frame.
- Install the necessary drivers to connect the Arduino Mega 2560 to the computer.
- Download the basic firmware configuration for the APM (check the datasheet for current specifications).
- Physically connect the flight controller to the Arduino Mega 2560 following the provided electrical diagrams.
- Configure the APM2.52 through the Mission Planner console (download from the official website).
- Calibrate the IMU sensors to ensure stable and precise flight.
- Test the drone control system with short ground tests.
- Once the system effectiveness is verified, proceed to flight.
Mini project
Build a quadcopter drone autonomously in 30 minutes using the APM2.52 controller and following the provided instructions.
Common mistakes
- Do not calibrate the IMU sensors correctly before flight.
- Use low-quality LiPo batteries that can compromise the safety of the drone.
- Omit the installation of necessary drivers to connect to the computer.
- Do not test the control system on the ground before the flight.
Recommended accessories
- Compatible IMU sensors
- Propulsion motors and propellers
- Robust drone frame
- High-capacity LiPo battery
Frequently asked questions
How can I optimize the stability of my drone?
Calibrate the IMU sensors accurately and ensure the weight is balanced on the frame.
What is the difference between APM2.52 and previous versions?
Version 2.52 includes safety and precision improvements, check the datasheet for specific details.
Reviews
There are no reviews yet.