 EN
 IT Italiano
 ES Español
 FR Français
 DE Deutsch
Description
What it is
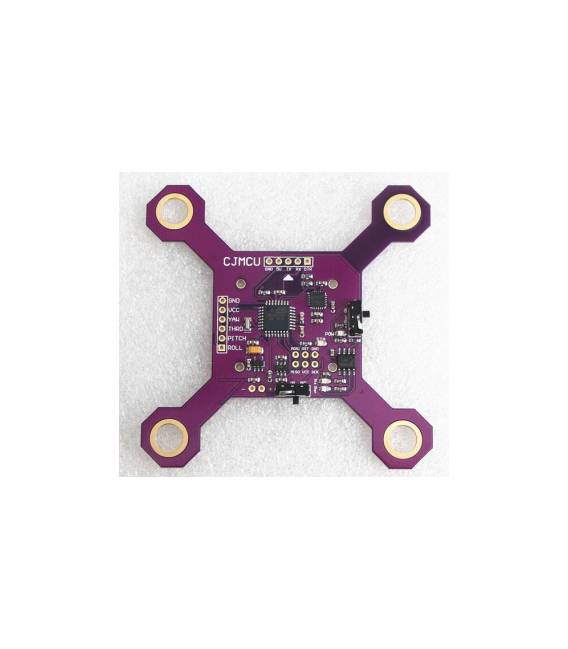
The Postura ATMEGA48 + MPU6050 Quadcopter 6Dof is a drone stabilization system that combines the power of the ATMEGA48 with the 6DoF MPU6050 sensor. This device is designed to measure the orientation and angular velocity of the quadcopter, providing key data for its stability during flight.
Features
- 6DoF MPU6050 sensor
- Integrated ATMEGA48 microcontroller
What it is for
Beginners and RC enthusiasts can use this component to build an advanced stabilization system for their drones. It is ideal for DIY projects where monitoring the orientation and angular velocity of the quadcopter is necessary.
Tutorial: How to use Postura ATMEGA48 + MPU6050
The Postura ATMEGA48 + MPU6050 is a 6DoF sensor used to measure the orientation and angular velocity of a quadcopter. Useful for beginners and intermediates.
What you need
- Arduino IDE
- USB cable
- Quadcopter
- MPU6050 library
Steps
- 1. Install Arduino IDE.
- 2. Connect Postura ATMEGA48 + MPU6050 to quadcopter.
- 3. Download MPU6050 library.
- 4. Check datasheet for pin configuration.
- 5. Write code to initialize the sensor.
- 6. Read orientation and angular velocity data.
- 7. Check quadcopter stability.
- 8. Test implementation.
Example code
```cpp
#include <Wire.h>
#include <MPU6050.h>

MPU6050 mpu;

void setup() {
  Wire.begin();
  mpu.initialize();
}

void loop() {
  Serial.print(mpu.getAccX());
  Serial.print(" ");
  Serial.println(mpu.getAccY());
}
```
Mini project
Build a simple graphical interface to display orientation data.
Common mistakes
- Incorrect pin connection.
- Library not up to date.
- Incorrect code.
- Data not displayed correctly.
Recommended accessories
- OLED display
- LiPo battery
- Wooden frame
- Quadcopter motor
Frequently asked questions
How can I check the stability of the quadcopter?
Use orientation data to control the position and orientation of the quadcopter.
Which pins to use?
Check the datasheet for specific pin usage.
Does Postura work with other microcontrollers?
Check the datasheet for compatibility.
What are the power requirements?
Check the datasheet for power requirements.
Reviews
There are no reviews yet.