 EN
 IT Italiano
 ES Español
 FR Français
 DE Deutsch
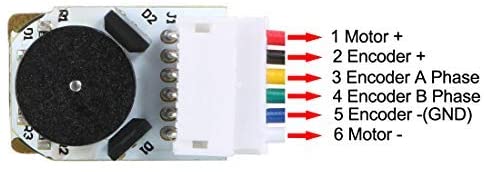
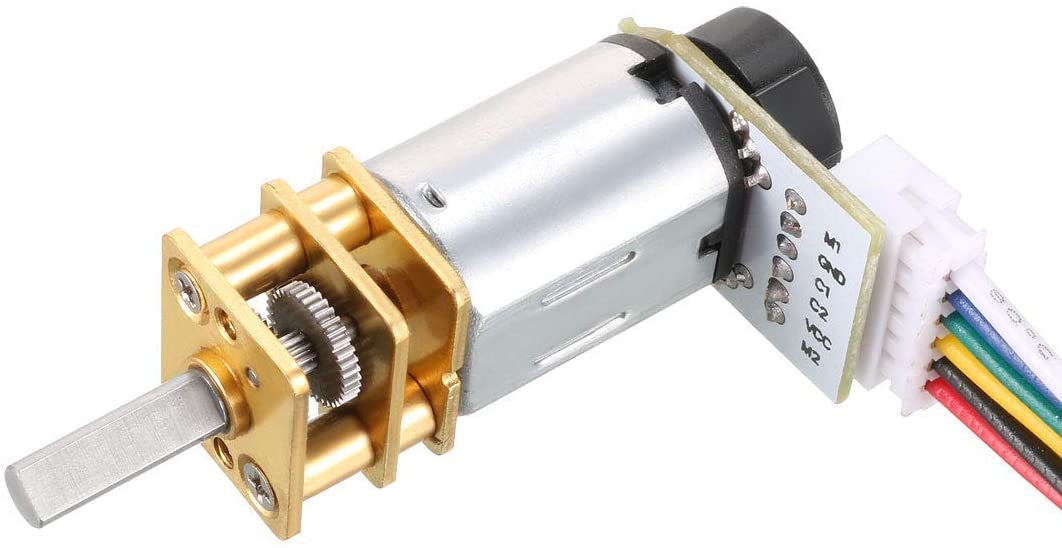
Description
What it is
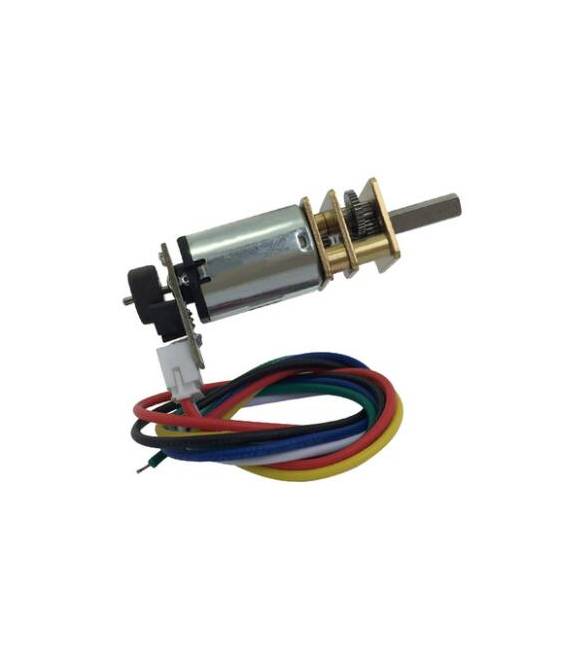
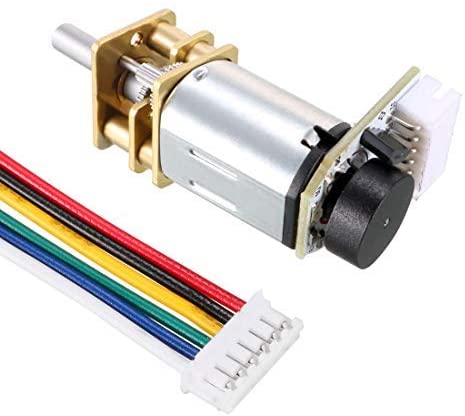
The micro-metal gear motor with encoder 6V 150 RPM 100:1 is an electronic component that combines a motor with a speed reducer and an encoder. The reducer allows for a lower rotational speed compared to the motor, while the encoder provides a digital signal indicating the position and rotation of the motor.
Features
- Supply Voltage: 6V
- Rotational Speed: 150 RPM
- Reduction Ratio: 100:1
- Materials: metal
What it is for
This gear motor is ideal for robotics projects, precision devices, and mechanical prototypes that require precise control of position and speed. It can be used to drive wheels, robotic arms, or other mechanical components. Compatibility with Arduino and ESP is verified in the datasheet.
Tutorial: How to use Micro-metal gear motor with encoder 6V 150 RPM 100:1
The micro-metal gear motor with encoder is ideal for projects requiring precision and detailed control, such as robotics, precision devices, and mechanical prototypes. It is suitable for beginner and intermediate makers who want to explore motor control.
What you need
- Arduino
- Connections
- Programming Software
- Batteries or Power Supply
- Additional Sensors (optional)
- 3D Printing for Prototypes (optional)
Steps
- Connect the gear motor to the power supply circuit (6V)
- Connect the gear motor to the Arduino using the appropriate connectors
- Configure the software to read the encoder signals
- Write an Arduino sketch to control the motor
- Test the motor with various speed and direction commands
- Verify that the encoder is functioning correctly
- Optimize the sketch to improve precision
- Design a mechanical prototype for the motor
Example code
void setup() {
  // Configura i pin del motoriduttore
}

void loop() {
  // Controlla il motore con comandi di velocità e direzione
}
Mini project
Basic Project: Build a small robot that moves based on the encoder commands. Use the gear motor to guide the robot and the encoder to control its position.
Common mistakes
- Incorrect connection between Arduino and gear motor
- Incorrect software settings for the encoder
- Insufficient power supply for the motor
- Synchronization issues between motor and encoder
Recommended accessories
- Connections for Arduino
- Batter or power supply for Arduino
- 3D printing for prototypes
- Position sensors
Frequently asked questions
How can I control the motor speed?
Modify the sketch to adjust the speed commands.
What is the difference between an encoder and a potentiometer?
The encoder provides precise information about the motor’s position and speed, while the potentiometer adjusts the electrical resistance.



Reviews
There are no reviews yet.