 EN
 IT Italiano
 ES Español
 FR Français
 DE Deutsch
Description
What it is
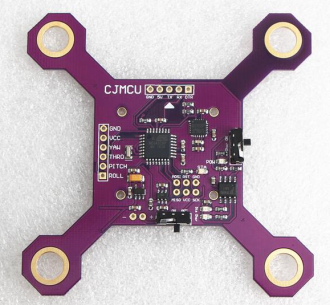
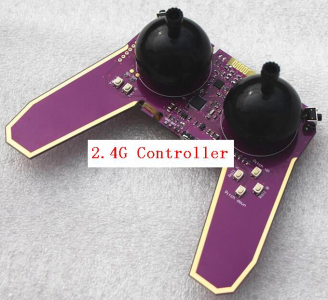
The 9DOF STM32F103 Quadcopter Controller is a module for drones that integrates high-precision sensors and a powerful microcontroller. This device combines an accelerometer, gyroscope, and magnetometer to provide data on position and orientation.
Features
- 9DOF Sensor (MPU6050 + HMC5883L)
- STM32F103 Microcontroller
What it is for
Ideally suited for makers who want to build an autonomous drone, this module can be used to stabilize the quadcopter’s flight and acquire data on position and orientation. It is compatible with Arduino.
Tutorial: How to Use Quadcopter 9DOF STM32F103 + MPU6050 + HMC5883L
The 9DOF STM32F103 quadcopter with accelerometer and gyroscope MPU6050, and magnetometer HMC5883L is ideal for makers who want to build an autonomous drone. This module offers a combination of integrated 9DOF (degrees of freedom) sensors with a powerful STM32F103 microcontroller, making it suitable for both manual piloting and automated flight.
What you need
- Arduino IDE
- USB A-B cable
- STM32 development software (optional)
- Arduino libraries for MPU6050 and HMC5883L
Steps
- Connect the quadcopter to the computer via USB cable.
- Install the necessary libraries for the sensors in Arduino IDE (check the datasheet).
- Load a sample sketch that reads data from the sensors and sends it to the serial monitor (check the datasheet).
- Verify the correct reception of data on the serial monitor.
- Configure the quadcopter for flight use, adjusting PID if necessary.
- Test the quadcopter on a stable and safe surface.
Example code
// Esempio di codice Arduino
#include <Wire.h>
#include <MPU6050.h>
#include <HMC5883L.h>

MPU6050 accelgyro;
HMC5883L compass;
void setup() {
  Serial.begin(9600);
  Wire.begin();
  accelgyro.initialize();
  compass.initialize();
}
void loop() {
  if (accelgyro.getMotion6(&ax, &ay, &az, &gx, &gy, &gz)) {
    Serial.print(ax); Serial.print(", "); Serial.print(ay); Serial.print(", "); Serial.println(az);
  }
  compass.read(compassData);
  Serial.print("X: "); Serial.print(compassData.x);
  Serial.print(" Y: "); Serial.print(compassData.y);
  Serial.print(" Z: "); Serial.println(compassData.z);
}
Mini project
Build a stabilization system for the drone using data acquired from the sensors.
Common mistakes
- Library installation error
- Incorrect PID configuration
- Unstable USB connection
Recommended accessories
- WiFi antennas
- Ultrasonic distance sensors
- Compatible LiPo batteries
- Logic programmer for STM32 (ST-Link)
Frequently asked questions
What is the minimum operating voltage?
Check the module’s datasheet.
How much weight can the quadcopter carry?
The payload capacity depends on the electronic and mechanical configuration, check the specific details of the model.
Reviews
There are no reviews yet.