 EN
 IT Italiano
 ES Español
 FR Français
 DE Deutsch
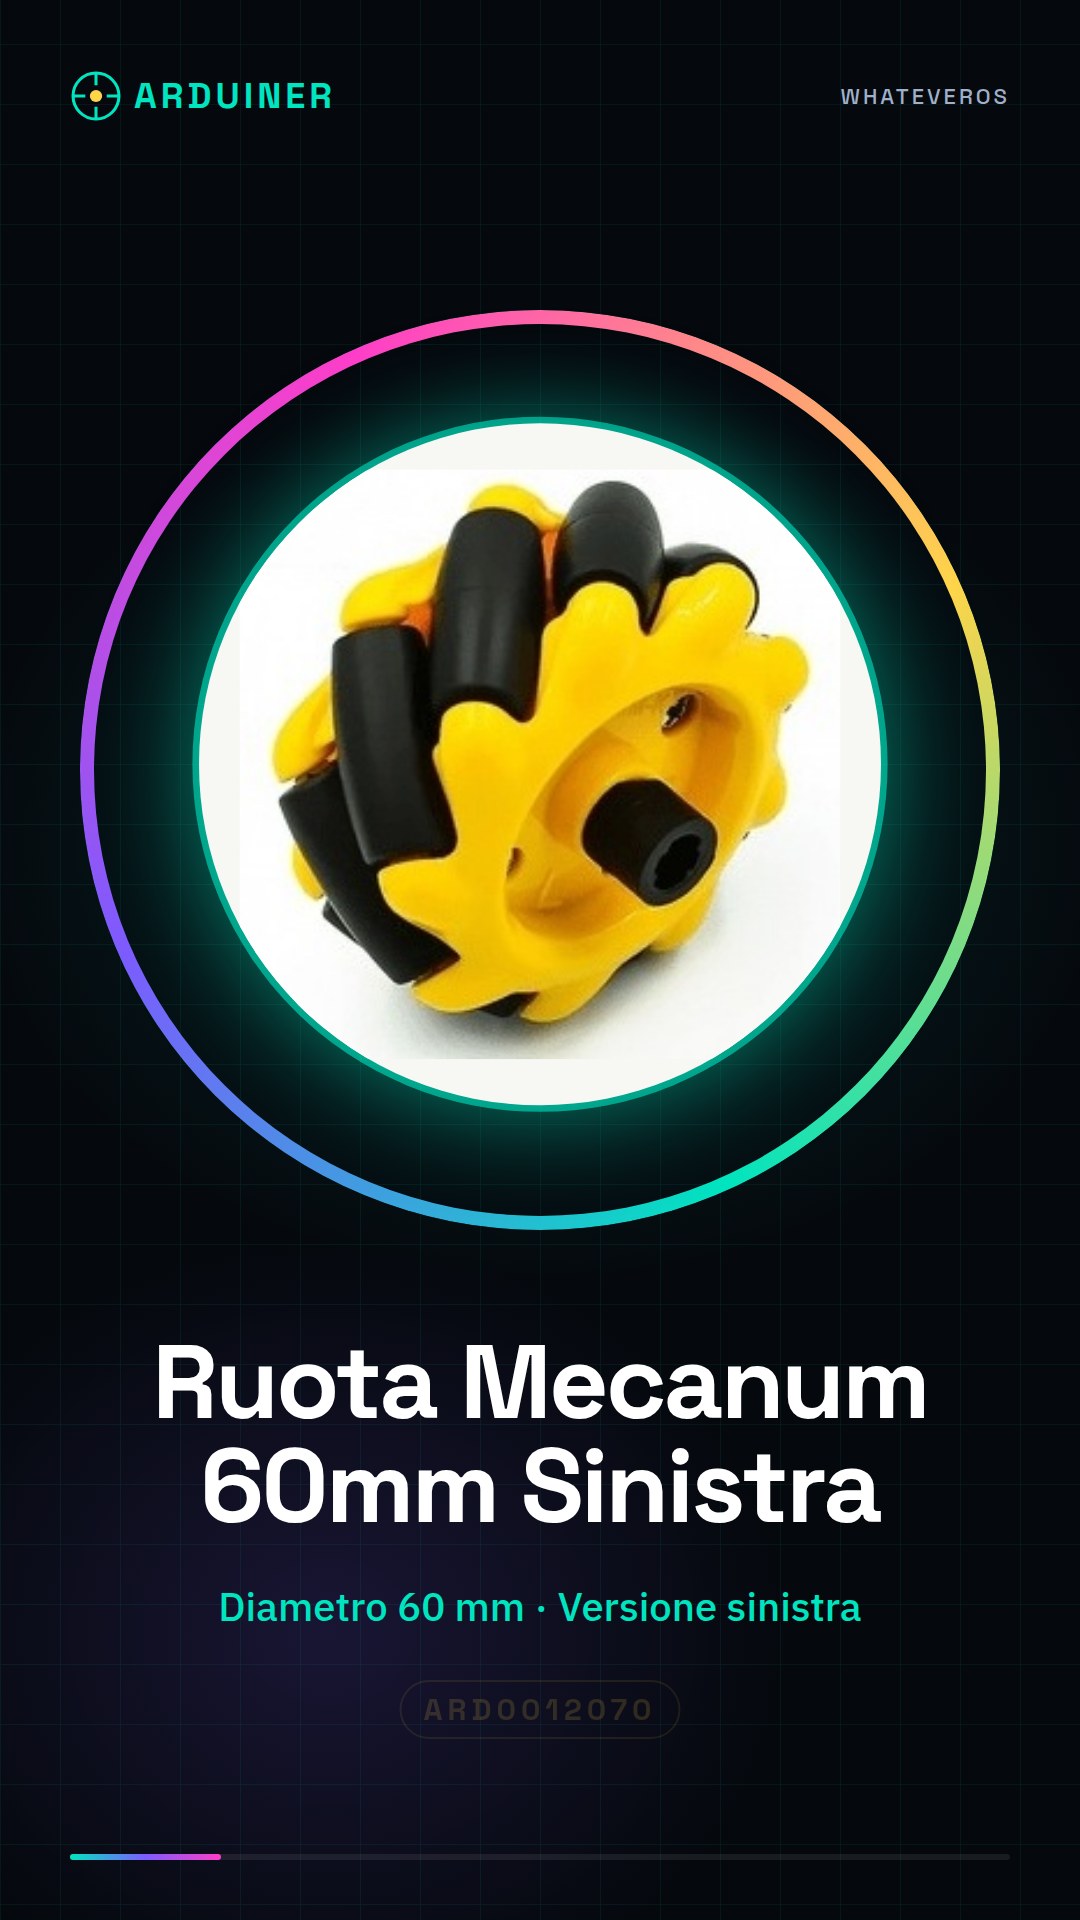
Description
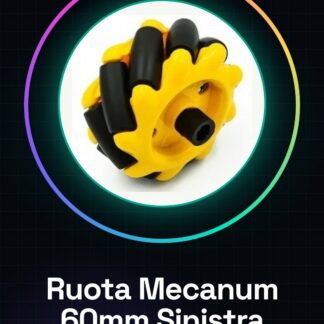
What is the Left Mecanum Wheel 60 mm? The Left Mecanum Wheel 60 mm is a crucial component for robotics projects that require multi-directional movement. This wheel allows robots to move in any direction without needing to turn, making them perfect for both beginners and experienced robot creators. Features Diameter: 60 mm Version: left What it’s used for These wheels are ideal for creating autonomous robots and vehicles requiring optimized mobility on flat surfaces. Using a Left Mecanum Wheel 60 mm, a chassis, a motor, and a motor controller, you can create an omnidirectional robot in 30 minutes. Compatibility with Arduino and ESP32 makes these components suitable for robotics and 3D printing projects. Tutorial: How to use the Left Mecanum Wheel 60 mm The Left Mecanum Wheels 60 mm are ideal for omnidirectional robotics projects. These components allow robots to move in any direction without needing to turn, making them perfect for both beginners and experienced robot creators. What you need Robot chassis Motor Motor controller Power connections Control connections Assembly kit Steps Mount the Mecanum wheel on the robot chassis using the provided screws and nuts. Connect the motor to the Mecanum wheel according to the motor specifications. Connect the motor controller to the motor and power source. Configure the motor controller to control the Mecanum wheel. Check the electrical connection between the motor controller and microcontroller (e.g., Arduino). Write an Arduino sketch to control the movement of the Mecanum wheel. Test the movement of the Mecanum wheel to ensure it works correctly. Optimize robot movement by adjusting motor control parameters. Example code void setup() { Serial.begin(9600); } void loop() { // Insert here the code to control the Mecanum wheel } Mini-project Create an omnidirectional robot in 30 minutes using a Left Mecanum Wheel 60 mm, chassis, motor, and motor controller. Common mistakes Not checking electrical connections before testing movement. Incorrectly configuring the motor controller. Writing incorrect Arduino sketch for controlling the Mecanum wheel. Failing to optimize robot movement after initial testing. Recommended accessories DC Motor 12V L298N Motor Controller Robot Chassis Assembly Kit Power Supply
Reviews
There are no reviews yet.