 EN
 IT Italiano
 ES Español
 FR Français
 DE Deutsch
Description
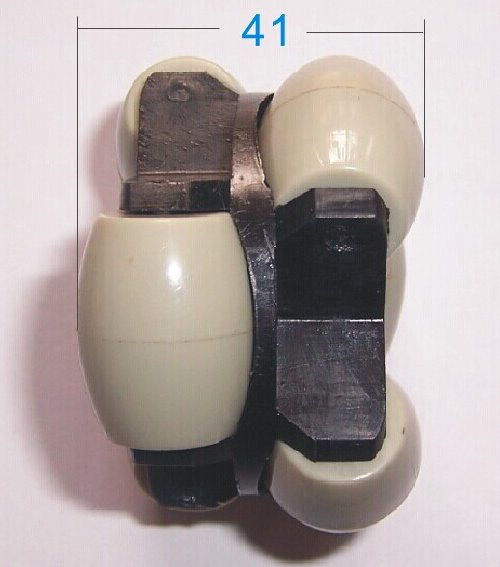
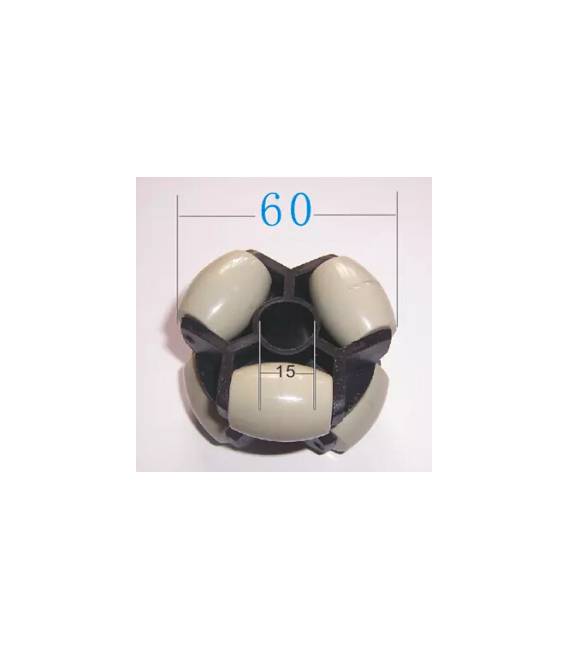
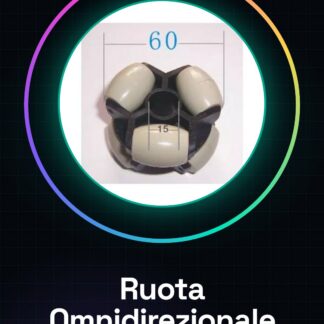
The 60mm omnidirectional wheel is a crucial component for robotic projects such as smart cars, robots, and rovers. This wheel enables complex movements in any direction without the need to turn. Features Diameter: 60mm What is it for The omnidirectional wheel is ideal for implementing multi-directional movements in robotics projects. You can use it in smart cars or rovers to create devices that can move freely in any direction. Tutorial: How to Use 60mm Omnidirectional Wheel The 60mm omnidirectional wheel is perfect for implementing complex and multi-directional movements in your robotics projects, such as smart cars or rovers. This component allows you to create devices that can move in any direction without the need to turn. What is needed DC Motor Arduino Uno or compatible Motor connection to Arduino Jumper wires Connect the motor to the motor driver Connect the motor driver to the Arduino Check the polarity of the connectors to avoid damage Upload the example sketch to the Arduino Configure the software to regulate speed and direction Install the omnidirectional wheel on the motor Test the system with small multi-directional movements Optimize control parameters Mini-project Create a smart car rover that can move in any direction without turning. Use the accelerometer to control the movement. Common errors Incorrect connection between motor and Arduino Incorrect polarity of connectors Incorrect motor driver configuration Omnidirectional wheel not installed correctly on the motor Recommended accessories Motor driver L298N Motor connection wires Various jumpers Accelerometer MPU6050 Frequently Asked Questions How can I adjust the speed of the wheel? Use the motor control software to change the speed parameters. What is the difference between an omnidirectional wheel and a regular wheel? An omnidirectional wheel can move in any direction without turning, while a regular wheel can only move forward and backward or side to side.
Reviews
There are no reviews yet.